Projects
Autonomy for uncrewed systems
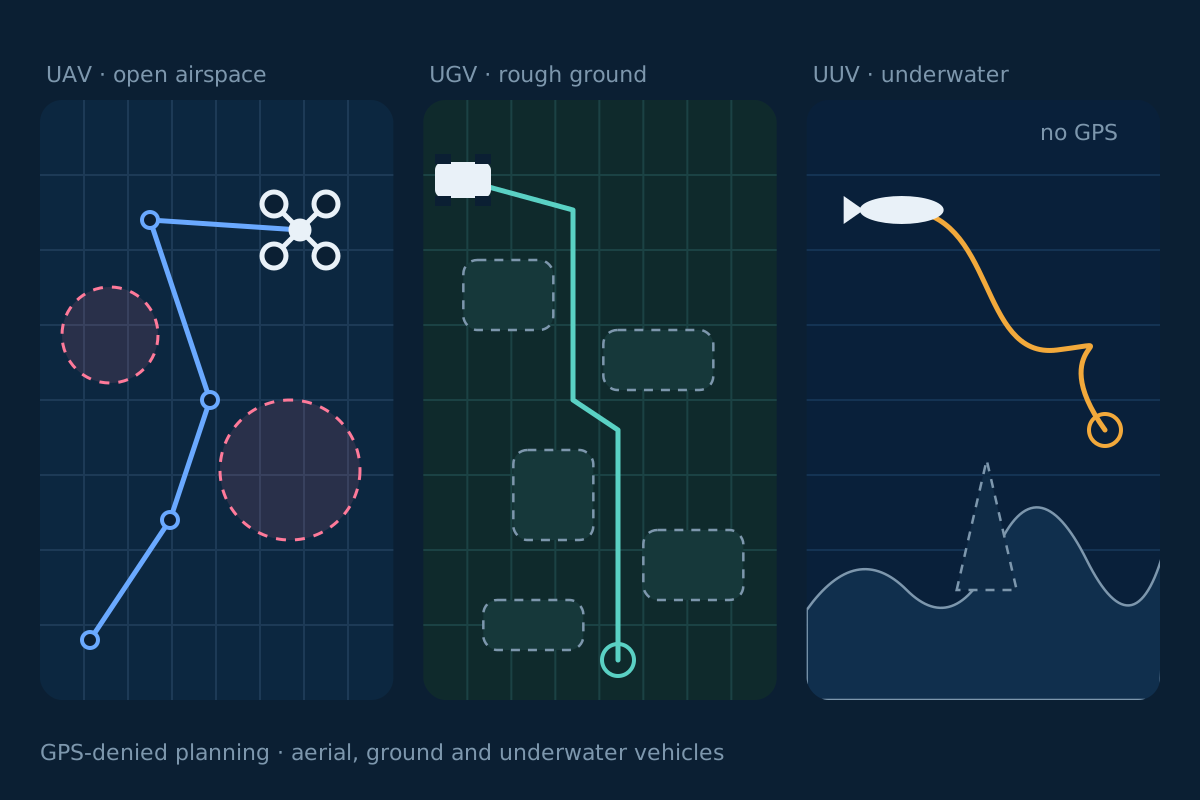
Path planning and multi-agent coordination for aerial, ground and underwater robots without GPS, running on edge hardware.
- Role
- Software Engineer, Robotics and AI (contract)
- When
- Aug 2022 to Jun 2023
- Organisation
- UTS Robotics Institute
- Stack
- Python, ROS, MQTT, edge hardware
The problem
An industry-funded research project aimed at fully autonomous UAVs, UGVs and UUVs working in GPS-denied environments, where a robot cannot rely on satellite positioning and has to coordinate with others on its own.
What I did
- Developed production-grade AI and robotics software for the project.
- Implemented and optimised autonomous path planning, multi-agent coordination and decision-making algorithms for uncrewed systems.
- Converted academic robotics and swarm-intelligence research into embedded software optimised for edge hardware.
- Integrated onboard and third-party components, including computer vision, over MQTT for real-time operation.
What came of it
Project milestones were delivered, and that contributed to a major contract extension for the next stage of the program.